Ruihao Zeng

Hi, I am Ruihao (Andrew) Zeng, a Ph.D. student in TransportLab, School of Civil Engineering, The University of Sydney, supervised by Assoc. Prof. Mohsen Ramezani and Prof. David Levinson. My Ph.D. (2024 – 2027) is supported by the Australian Government Research Training Program (RTP) Scholarship, and my thesis is on Distributed Intelligence in Systems of Autonomous Vehicles.

My research focuses on Distributed / Decentralised Autonomous Vehicles, Deep Reinforcement Learning for Multi-agent Vehicle Control, 3D Perception and Multi-object Tracking with LiDAR, and Spatio-temporal Traffic Prediction. I like building end-to-end systems, from data pipelines and large-scale simulation to real-time deployment in the cloud. I hope to use intelligent methods to solve problems in transportation and society.

Before my Ph.D., I completed an M.Phil. in Transportation at TransportLab (2022 – 2023) with High Distinction. My M.Phil. thesis was Online Multi-Object Tracking Using LiDAR, and I received the Paulette Isabel Jones Career Development Award. I received my B.E. degree in Digital Media Technology & Computer Science in 2022, graduating first in my cohort as the valedictorian.

From November 2020 to December 2022, I worked as a research assistant at the Institute of Transportation Big Data of Digital Fujian, co-advised by Xing Wang and Fumin Zou, developing deep-learning models for traffic flow prediction, trajectory prediction and traffic-anomaly detection on city-wide sensor data (7M+ records). I also worked for a summer research program on GAN-based line art colorization at Massachusetts Institute of Technology in 2021, supervised by Mark Vogelsberger.

E-mail  |  Google Scholar  |  GitHub  |  LinkedIn

profile photo Photo by Andrew
Updates
  • [Aug 2026] Oral presentation at the 23rd IFAC World Congress, Busan, South Korea.
  • [Aug 2026] Our paper "Deep Reinforcement Learning for Communication-Free Distributed Control of Autonomous Vehicles in Unstructured Intersection" was published in IEEE Transactions on Cybernetics!
  • [2026] Oral presentation at the IEEE ITSS NSW Chapter Inaugural Meetup, Sydney, Australia.
  • [2026] Co-authored paper "FedTETP: Federated learning with topology enhancement for traffic prediction" was accepted by Future Generation Computer Systems.
  • [2025] Our paper "A dynamic-confidence 3D multi-object tracking method based on spatio-temporal association" was published in Measurement!
  • [Jul 2025] Oral presentation at the TRB Traffic Flow Theory and Characteristics Committee (TFTC) Summer Meeting – Symposium on Advancing Traffic Flow Theory for a Sustainable Future, Cairns, Australia.
  • [May 2025] Poster presentation at the Transportation Research Symposium (TRS 2025), Rotterdam, Netherlands.
  • [2025] Poster presentation at the Transport Research Association for NSW (TraNSW) Annual Symposium, Sydney, Australia.
  • [2025] Co-authored papers were published in Applied Intelligence (DSTSPYN), Neurocomputing (DSTF) and Expert Systems with Applications (FedCTPM).
  • [2024] Started my Ph.D. at TransportLab, The University of Sydney, supported by the Australian Government RTP Scholarship.
  • [Jan 2024] Poster presentation at the Transportation Research Board Annual Meeting (TRBAM 2024), Washington, D.C., USA.
  • [2024] Oral presentation at the TraNSW Annual Symposium, Sydney, Australia.
  • [2023] Completed my M.Phil. with High Distinction and received the Paulette Isabel Jones Career Development Award.
  • [2023] Most Innovative Award at the SCATS Student Traffic Data Innovation Challenge (NSW Government & iMOVE).
  • [2023] Oral presentation at the TraNSW Annual Symposium, Sydney, Australia.
  • [2023] Poster presentation at the HDR Conference, Faculty of Engineering, The University of Sydney.
  • [Oct 2022] Our paper "STTF: An efficient transformer model for traffic congestion prediction" was accepted by International Journal of Computational Intelligence Systems.
  • [Oct 2022] START my research journey in TransportLab, The University of Sydney!
  • [Aug 2021] Our paper "A highly efficient framework for outlier detection in urban traffic flow" was accepted by IET Intelligent Transport Systems, Congrats :)
Publications

Full list on Google Scholar. Representative papers are highlighted. * denotes the corresponding author.

Deep Reinforcement Learning for Communication-Free Distributed Control of Autonomous Vehicles in Unstructured Intersection
Ruihao Zeng and Mohsen Ramezani
IEEE Transactions on Cybernetics, 2026, Q1
[paper]

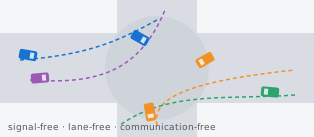
A continuous-PPO framework with curriculum learning and a reference-action-guided loss that controls acceleration and steering of autonomous vehicles in signal-free, lane-free intersections without any inter-vehicle communication. A rule-embedded hybrid policy supports long-term deployment safety: over 100M+ km of cumulative simulation, only 36 collisions were recorded.

TransportLab, The University of Sydney.

A Dynamic-Confidence 3D Multi-Object Tracking Method Based on Spatio-Temporal Association
Ruihao Zeng and Mohsen Ramezani
Measurement, vol. 256, 117864, 2025, Q1
[paper]

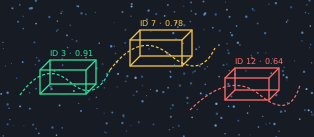
An online LiDAR-based 3D multi-object tracking method for moving sensors: a constant-acceleration motion model with orientation variation, a spatio-temporal feature-based data association model, and a dynamic confidence threshold to keep tracking temporarily occluded objects. Evaluated on KITTI and nuScenes.

Resulted from my M.Phil. thesis at TransportLab, The University of Sydney.

STTF: An Efficient Transformer Model for Traffic Congestion Prediction
Xing Wang, Ruihao Zeng*, Fumin Zou, Lyuchao Liao and Faliang Huang
International Journal of Computational Intelligence Systems, 2023, Q2
[paper]

Institute of Transportation Big Data of Digital Fujian.

Supported by the Foreign Cooperation Project of Fujian Provincial Department of Science and Technology.

A Highly Efficient Framework for Outlier Detection in Urban Traffic Flow
Xing Wang, Ruihao Zeng*, Fumin Zou, Faliang Huang and Biao Jin
IET Intelligent Transport Systems, 2021, Q2
[paper]

Institute of Transportation Big Data of Digital Fujian.

Supported by the Natural Science Foundation of China and the Foreign Cooperation Project of Fujian Provincial Department of Science and Technology.

Co-authored papers
Projects
Multi-Agent Self-Adaptive Framework for Portfolio Risk Management
Feb. 2024 – Dec. 2024

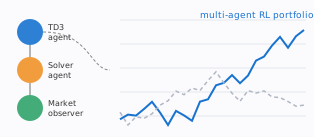
A triple-agent reinforcement-learning architecture (a TD3-based decision agent, a convex-optimisation solver agent and a market-observer agent) coupled in a loosely-coupled pipelining model, with Jensen–Shannon-divergence-based reward shaping to prevent policy collapse under volatile markets. Achieved a 22.49% annual return and a Sharpe ratio of 0.92 on the S&P 500, and outperformed 10 baselines (incl. EIIE, RAT, PPN) across CSI 300, DJIA and S&P 500 over a 10-year horizon.

POLD: Parking-Lot Occupancy LiDAR Detection
Jan. 2023 – Jul. 2023, TransportLab & Seoul Robotics
[code]

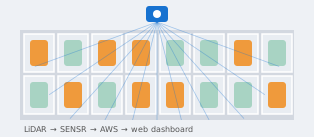
A real-time LiDAR system that detects parking occupancy and visualises results through AWS-hosted web applications. Built EC2-based scripts for point-cloud parsing, map construction and automated parking-space recognition, and integrated the SENSR perception software with AWS into a complete data-acquisition-to-cloud-deployment pipeline.

Lego ARCity
May 2023 – Dec. 2023, Outreach Office, School of Civil Engineering, The University of Sydney
[code]

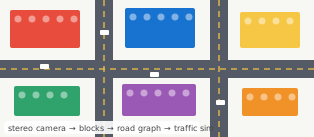
Stereo-camera computer vision detects Lego block layouts and reconstructs a virtual city in real time; road-network generation algorithms convert the physical layout into a digital graph, and a real-time traffic simulation visualises traffic flow on the user-created road structure.

HuBMAP - Hacking the Kidney
Tim biubiu, eric iii, Mroland2021, tedin and JODY JODY
Kaggle, 2021, Bronze Medal
[code]

Learned a lot :)

Awards & Conferences

Honors & Awards:

  • Most Innovative Award of SCATS Student Traffic Data Innovation Challenge (NSW Government & iMOVE). (2023)
  • Second Prize of National Student Mathematical Modeling Competition. (2021)
  • Bronze Medal of Kaggle HuBMAP Competition. (2021)
  • Honorable Mention of Interdisciplinary Contest in Modeling (ICM) & Mathematical Contest in Modeling (MCM). (2021)
  • First Prize of the 10th MathorCup College Mathematical Modeling Challenge. (2020)

Conferences:

  • Oral presentation, 23rd IFAC World Congress – Busan, South Korea. (2026)
  • Oral presentation, IEEE ITSS NSW Chapter Inaugural Meetup – Sydney, Australia. (2026)
  • Oral presentation, Summer Meeting of the Traffic Flow Theory and Characteristics Committee (TFTC) – Symposium on Advancing Traffic Flow Theory for a Sustainable Future – Cairns, Australia. (2025)
  • Poster presentation, Transportation Research Symposium (TRS) – Rotterdam, Netherlands. (2025)
  • Poster presentation, Transport Research Association for NSW (TraNSW) Annual Symposium – Sydney, Australia. (2025)
  • Poster presentation, Transportation Research Board Annual Meeting (TRBAM) – Washington, D.C., USA. (2024)
  • Oral presentation, Transport Research Association for NSW (TraNSW) Annual Symposium – Sydney, Australia. (2024)
  • Oral presentation, Transport Research Association for NSW (TraNSW) Annual Symposium – Sydney, Australia. (2023)
  • Poster presentation, HDR Conference, Faculty of Engineering, The University of Sydney – Sydney, Australia. (2023)
Experience
  • Exam Supervision Officer, The University of Sydney. (Jun. 2026 – Present)
  • Higher Degree Research (HDR) Student Representative, School of Civil Engineering, The University of Sydney. (Jan. 2025 – Present)
  • Tutor, Marker and Thesis Assessor, School of Civil Engineering, The University of Sydney. (Feb. 2023 – Present)
  • Research Project Mentor (Capstone & VRI), School of Civil Engineering, The University of Sydney – LiDAR-based pedestrian detection and parking-occupancy mapping. (Dec. 2023 – Oct. 2024)
  • Algorithm and Application Developer, Lego ARCity Project, Outreach Office of School of Civil Engineering, The University of Sydney. (May 2023 – Dec. 2023)
  • Researcher & Developer, Parking-Lot Occupancy LiDAR Detection (POLD), TransportLab & Seoul Robotics. (Jan. 2023 – Jul. 2023)
  • Urban Traffic Data Analyst, Service-Oriented Trajectory Prediction in Traffic Network, Institute of Transportation Big Data of Digital Fujian, Fuzhou, China. (Nov. 2020 – Dec. 2022)


Template modified from here.